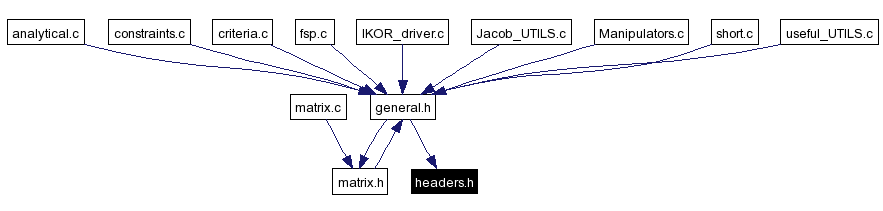
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Functions | |
| int | IKOR_driver (int *IKCriterion, int *IKMethod, int Optimization, int N_use, int M_use) |
| MATRIX * | CALC_PSEUDO (MATRIX *Jacob, MATRIX *dx) |
| MATRIX * | FSP (Solutions *FSP_data, History *Old_DQs, MATRIX *Jacob, MATRIX *dx, int *IKCriterion, int *IKMethod, int Optimization, int ns, double spheredata[4][4], MATRIX *x_of_link, FILE *datafp) |
| void | Euler_to_Velocities (MATRIX *x_of_link, MATRIX *dx) |
| float | correct_euler (float angle, float curr, float dest) |
| int | OPEN_FILES (double XTraj[MAX_PTS][6], char PoorMansFile[40], MATRIX *Qarray) |
| int | Init_Globals () |
| void | Update_History (History *Old_DQs, MATRIX *dq) |
| void | GET_JACOBIAN_ALTERED (MATRIX *Jacob, MATRIX *Qarray) |
| void | GET_JACOBIAN (MATRIX *Jacob, MATRIX *Qarray) |
| void | ExtractRPY2 (MATRIX *T, MATRIX *x_of_link) |
| MATRIX * | getT2 (double ZA, double YB, double XG, double tx, double ty, double tz) |
| void | GET_JACOB (MATRIX *Jacob, MATRIX *Qarray) |
| void | GET_ACTUAL_X (MATRIX *Qarray, MATRIX *x_of_link) |
| int | Solution_generator (Solutions *FSP_data, MATRIX *Jacob, MATRIX *dx, FILE *datafp) |
| void | RestofSoln (int Mred, int Nred, int NextToFind, MATRIX *block, MATRIX *g, MATRIX *bred, MATRIX *Ared, int *Tackon, int *FirstOK, FILE *check) |
| int | BLOCK_COL_FIND_X (int *Tackon, float *g, float *block, MATRIX *b, MATRIX *A, int Mred, int Nred, FILE *check) |
| int | ReduceA (Solutions *FSP_data, MATRIX *Aorig, MATRIX *Ared, MATRIX *borig, MATRIX *bred, int *ColElim, int *RowElim, int *NumSpg, MATRIX *Specialg) |
| int | CheckB (MATRIX *b, int m) |
| int | CheckRange (MATRIX *b, MATRIX *Aorig, MATRIX *g, int *RowElim, int Mred) |
| void | Rebuild_gs (Solutions *FSP_data, int *ColElim, MATRIX *Specialg, int NumSpg) |
| void | IKerror (int vector, int fatal, char *mesg) |
| Solutions * | Solutions_init (int M, int N) |
| void | Solutions_free (Solutions *Temp) |
| int | GetData (MATRIX *A, MATRIX *b) |
| int | spheres (double spheredata[4][4], FILE *datafp) |
| void | fmat_pr (FILE *checkfile, char *string, MATRIX *a) |
| void | fmat_prf (FILE *checkfile, char *string, MATRIX *a) |
| void | fprint_norm (FILE *checkfile, MATRIX *dq, FILE *datafp) |
| int | avoid_limits (Solutions *FSP_data, MATRIX *Jacob, MATRIX *dx, int *got_gs, FILE *datafp) |
| int | avoid_obstacles (Solutions *FSP_data, MATRIX *Jacob, MATRIX *dx, MATRIX *x_of_link, int ns, double spheredata[4][4], int *got_gs, FILE *datafp) |
| int | find_intersection_sphere (double pt1[3], double pt2[3], int ws, int ns, double spheredata[4][4], int *elbow_check, double *newl, double *delta, double normal[3], FILE *datafp) |
| int | Least_Norm (MATRIX *B, MATRIX *H, FILE *datafp) |
| int | Least_Flow (MATRIX *B, MATRIX *H, MATRIX *Qarray, FILE *datafp) |
| float | calc_flow (int index, float Q, float dq, float distance, MATRIX *old) |
| MATRIX * | Build_Grammian2 (Solutions *FSP_data, MATRIX *alphas, FILE *datafp) |
| void | rank_lost_betas (Solutions *FSP_data, MATRIX *Jacob, MATRIX *dx, int *RowElim, FILE *datafp) |
| void | find_jl_beta (Solutions *FSP_data, int chk, double limit, FILE *datafp) |
| void | find_obs_beta (Solutions *FSP_data, int chk, double *newl, double delta, double normal[3], FILE *datafp) |
| MATRIX * | findt_with_Betas_Holonomic (Solutions *FSP_data, MATRIX *B, MATRIX *H, FILE *datafp) |
| MATRIX * | findt_without_Betas_Holonomic (Solutions *FSP_data, MATRIX *B, MATRIX *H, FILE *datafp) |
| MATRIX * | findt_with_Betas_Nonholonomic (Solutions *FSP_data, MATRIX *B, MATRIX *H, FILE *datafp) |
| MATRIX * | findt_without_Betas_Nonholonomic (Solutions *FSP_data, MATRIX *B, MATRIX *H, FILE *datafp) |
| MATRIX * | findt_without_Betas_BANGBANG (Solutions *FSP_data, MATRIX *B, MATRIX *H, MATRIX *old, FILE *datafp) |
| MATRIX * | findt_without_Betas_SIMPLX (Solutions *FSP_data, MATRIX *B, MATRIX *H, FILE *datafp) |
| void | init_ARM () |
|
||||||||||||||||||||||||
|
Definition at line 36 of file constraints.c. References Manipulator_struct::Angles, datafp, DEBUG, deg, FALSE, find_jl_beta(), GET_JACOBIAN(), ANGLE::Max_limit, ANGLE::Min_limit, MATRIX::p, ANGLE::Prism, Solutions::Qarray, rad, Robot, Solution_generator(), STEP, TRUE, and TWO. Referenced by FSP(). |
|
||||||||||||||||||||||||||||||||||||
|
Referenced by FSP(). |
|
||||||||||||||||||||||||||||||||||||
|
Definition at line 559 of file fsp.c. References DEBUG_FSP, fmat_pr(), gcheck, mat_free(), mat_LU_inv(), mat_malloc(), mat_mul2(), and MATRIX::p. Referenced by RestofSoln(), and Solution_generator(). |
|
||||||||||||||||
|
Definition at line 364 of file analytical.c. References MATRIX::cols, datafp, DEBUG, fmat_pr(), Solutions::g, mat_cp(), mat_free(), mat_malloc(), mat_mul2(), MATRIX::p, Robot, MATRIX::rows, SPAN, and Manipulator_struct::Weights. Referenced by findt_with_Betas_Holonomic(), findt_with_Betas_Nonholonomic(), findt_without_Betas_Holonomic(), and findt_without_Betas_Nonholonomic(). |
|
||||||||||||||||||||||||
|
Definition at line 85 of file criteria.c. References datafp, DEBUG, distfp, FLWfile, PI, SPEED, SQUARE, and ZERO. Referenced by Least_Flow(). |
|
||||||||||||
|
Definition at line 419 of file IKOR_driver.c. References MATRIX::cols, datafp, DEBUG, fmat_pr(), fmat_prf(), mat_cp(), mat_free(), mat_malloc(), mat_mul2(), mat_pseudoinv(), and MATRIX::p. Referenced by IKOR_driver(). |
|
||||||||||||
|
Definition at line 1076 of file fsp.c. References MATRIX::p, and SMALL. Referenced by Solution_generator(). |
|
||||||||||||||||||||||||
|
Definition at line 1106 of file fsp.c. Referenced by Solution_generator(). |
|
||||||||||||||||
|
Definition at line 383 of file IKOR_driver.c. References datafp, DEBUG, and PI. Referenced by IKOR_driver(). |
|
||||||||||||
|
Definition at line 335 of file IKOR_driver.c. References datafp, DEBUG, Manipulator_struct::NL, MATRIX::p, and Robot. Referenced by IKOR_driver(). |
|
||||||||||||
|
Definition at line 110 of file Jacob_UTILS.c. References MATRIX::cols, datafp, Manipulator_struct::NL, MATRIX::p, PI, Robot, SMALL, and ZERO. |
|
||||||||||||||||||||||||||||||||||||||||||||
|
Referenced by avoid_obstacles(). |
|
||||||||||||||||||||
|
Definition at line 438 of file analytical.c. References Solutions::betall, Solutions::cn, MATRIX::cols, datafp, Solutions::g, MATRIX::p, and MATRIX::rows. Referenced by avoid_limits(). |
|
||||||||||||||||||||||||||||
|
Referenced by avoid_obstacles(). |
|
||||||||||||||||||||
|
Definition at line 653 of file analytical.c. References Solutions::betall, Build_Grammian2(), Solutions::cn, MATRIX::cols, datafp, DEBUG, FATAL, fmat_pr(), fmat_prf(), Solutions::g, IKerror(), Solutions::M, mat_cp(), mat_cp2(), mat_free(), mat_LU_inv(), mat_malloc(), mat_mul2(), Solutions::Null_Space, ONE, MATRIX::p, MATRIX::rows, SPAN, STEP, and TWO. Referenced by FSP(). |
|
||||||||||||||||||||
|
Definition at line 1074 of file analytical.c. References Solutions::betall, Build_Grammian2(), Solutions::cn, datafp, DEBUG, FATAL, fmat_pr(), Solutions::g, IKerror(), Platform::Length, Solutions::M, mat_add(), mat_cp2(), mat_free(), mat_LU_inv(), mat_malloc(), mat_mul(), mat_mul2(), mat_sca(), mat_sub(), mat_tra(), Solutions::Null_Space, ONE, MATRIX::p, PI, Manipulator_struct::PLAT, Solutions::Qarray, Robot, SPAN, STEP, and TWO. Referenced by FSP(). |
|
||||||||||||||||||||||||
|
Definition at line 550 of file analytical.c. References MATRIX::cols, datafp, DEBUG, FALSE, FATAL, fmat_pr(), Solutions::g, IKerror(), Solutions::M, mat_free(), mat_malloc(), Solutions::Null_Space, OK, ONE, MATRIX::p, SPAN, STEP, TRUE, TWO, and ZERO. Referenced by FSP(). |
|
||||||||||||||||||||
|
Definition at line 953 of file analytical.c. References Build_Grammian2(), MATRIX::cols, datafp, DEBUG, FATAL, fmat_pr(), Solutions::g, IKerror(), mat_add(), mat_cp2(), mat_free(), mat_LU_inv(), mat_malloc(), mat_mul2(), mat_sca(), Solutions::Null_Space, MATRIX::p, MATRIX::rows, and SPAN. Referenced by FSP(). |
|
||||||||||||||||||||
|
Definition at line 1538 of file analytical.c. References Build_Grammian2(), Solutions::cn, datafp, DEBUG, fmat_pr(), Solutions::g, IKerror(), Platform::Length, Solutions::M, mat_add(), mat_cp2(), mat_free(), mat_LU_inv(), mat_malloc(), mat_mul(), mat_mul2(), mat_sca(), Solutions::Null_Space, OK, MATRIX::p, PI, Manipulator_struct::PLAT, Solutions::Qarray, Robot, and SPAN. Referenced by FSP(). |
|
||||||||||||||||||||
|
Definition at line 275 of file analytical.c. References MATRIX::cols, datafp, DEBUG, FATAL, fmat_pr(), Solutions::g, IKerror(), Solutions::M, mat_malloc(), mysimplx(), Solutions::Null_Space, OK, ONE, MATRIX::p, SPAN, STEP, TWO, and ZERO. Referenced by FSP(). |
|
||||||||||||||||
|
Definition at line 271 of file useful_UTILS.c. References MATRIX::cols, MATRIX::p, and MATRIX::rows. Referenced by avoid_obstacles(), BLOCK_COL_FIND_X(), Build_Grammian2(), CALC_PSEUDO(), find_obs_beta(), findt_with_Betas_Holonomic(), findt_with_Betas_Nonholonomic(), findt_without_Betas_BANGBANG(), findt_without_Betas_Holonomic(), findt_without_Betas_Nonholonomic(), findt_without_Betas_SIMPLX(), IKOR_driver(), Least_Flow(), Least_Norm(), OPEN_FILES(), RestofSoln(), and Solution_generator(). |
|
||||||||||||||||
|
Definition at line 286 of file useful_UTILS.c. References MATRIX::cols, MATRIX::p, and MATRIX::rows. Referenced by CALC_PSEUDO(), findt_with_Betas_Holonomic(), and IKOR_driver(). |
|
||||||||||||||||
|
Definition at line 317 of file useful_UTILS.c. Referenced by IKOR_driver(). |
|
||||||||||||||||||||||||||||||||||||||||||||||||
|
|
|
||||||||||||
|
Referenced by avoid_obstacles(), and IKOR_driver(). |
|
||||||||||||
|
Referenced by GET_JACOBIAN(), and GET_JACOBIAN_ALTERED(). |
|
||||||||||||
|
Definition at line 38 of file Jacob_UTILS.c. References GET_JACOB(), Manipulator_struct::LINKS, LL, Manipulator_struct::NL, and Robot. Referenced by avoid_limits(), avoid_obstacles(), and IKOR_driver(). |
|
||||||||||||
|
Definition at line 46 of file Jacob_UTILS.c. References GET_JACOB(). Referenced by find_obs_beta(). |
|
||||||||||||
|
Definition at line 156 of file useful_UTILS.c. References MATRIX::p. Referenced by IKOR_driver(). |
|
||||||||||||||||||||||||||||
|
Definition at line 70 of file Jacob_UTILS.c. References mat_malloc(), and MATRIX::p. |
|
||||||||||||||||
|
Definition at line 38 of file useful_UTILS.c. References FATAL, Manipulator_struct::NA, and Robot. Referenced by findt_with_Betas_Holonomic(), findt_with_Betas_Nonholonomic(), findt_without_Betas_BANGBANG(), findt_without_Betas_Holonomic(), findt_without_Betas_Nonholonomic(), findt_without_Betas_SIMPLX(), FSP(), go_next(), IKOR_driver(), init_ARM(), Init_Globals(), main(), OPEN_FILES(), rm_blanks(), Solution_generator(), Solutions_init(), and spheres(). |
|
||||||||||||||||||||||||
|
Definition at line 52 of file IKOR_driver.c. References Manipulator_struct::Angles, BIG, CALC_PSEUDO(), CheezyFile, Solutions::cn, MATRIX::cols, correct_euler(), datafp, DEBUG, History::dq, History_Element::DQ, dqfile, dxLabel, ErrorFile, Euler_to_Velocities(), fmat_pr(), fmat_prf(), fprint_norm(), FSP(), GET_ACTUAL_X(), GET_JACOBIAN(), GetData(), HIST_SIZE, IKerror(), LL, mat_free(), mat_malloc(), mat_mul(), MAX_PTS, Manipulator_struct::NA, Manipulator_struct::NL, NormFile, OK, OPEN_FILES(), Manipulator_struct::Orient, MATRIX::p, PI, PoorMansFile, ANGLE::Prism, Solutions::Qarray, Robot, MATRIX::rows, SMALL, Solutions_free(), Solutions_init(), spheres(), STEP, Update_History(), Manipulator_struct::Weights, History::whereami, Solutions::Xelim, ZERO, and ZEROD_OMEGAS. Referenced by main(). |
|
|
Definition at line 86 of file Manipulators.c. References Platform::ANG_OFF, Manipulator_struct::Angles, ARM_file, DEBUG, EExaxis, EEyaxis, EEzaxis, Platform::Exist, FALSE, FATAL, go_next(), Platform::Holonomic, ANGLE::Home, IKerror(), Platform::L_OFF, Platform::Length, Manipulator_struct::LINKS, LL, mat_malloc(), ANGLE::Max_limit, ANGLE::Min_limit, Manipulator_struct::NA, Manipulator_struct::NL, MATRIX::p, PI, Manipulator_struct::PLAT, ANGLE::Prism, rm_blanks(), Robot, Platform::Thick, TRUE, Manipulator_struct::Weights, Platform::Width, and Platform::Z_OFF. Referenced by Init_Globals(). |
|
|
Definition at line 728 of file IKOR_driver.c. References all_links, datafp, E1, E2, E3, E4, EW1, EW2, EW3, EW4, Platform::Exist, FATAL, IKerror(), init_ARM(), Platform::Length, link_location, Manipulator_struct::LINKS, mat_malloc(), Manipulator_struct::NL, MATRIX::p, P2, P3, P4, Manipulator_struct::PLAT, PW1, PW2, PW3, PW4, Robot, RW, Platform::Width, XW, and ZERO. Referenced by main(). |
|
||||||||||||||||||||
|
Definition at line 64 of file criteria.c. References calc_flow(), MATRIX::cols, datafp, DEBUG, fmat_pr(), MATRIX::p, MATRIX::rows, and ZERO. Referenced by FSP(). |
|
||||||||||||||||
|
Definition at line 31 of file criteria.c. References MATRIX::cols, datafp, DEBUG, fmat_pr(), MATRIX::p, MATRIX::rows, and ZERO. Referenced by FSP(). |
|
||||||||||||||||
|
|
|
||||||||||||||||||||||||
|
|
|
||||||||||||||||||||
|
Definition at line 1152 of file fsp.c. References Solutions::g, Solutions::M, mat_cp2(), mat_free(), Solutions::Mred, Solutions::Nred, MATRIX::p, MATRIX::rows, and ZERO. Referenced by Solution_generator(). |
|
||||||||||||||||||||||||||||||||||||||||
|
Definition at line 664 of file fsp.c. References Dependency(), FALSE, Solutions::M, mat_free(), mat_malloc(), mat_null(), Solutions::Mred, Solutions::Nred, Solutions::Null_Space, MATRIX::p, MATRIX::rows, SMALL, TRUE, and Solutions::Xelim. Referenced by Solution_generator(). |
|
||||||||||||||||||||||||||||||||||||||||||||
|
Definition at line 351 of file fsp.c. References BLOCK_COL_FIND_X(), DEBUG_FSP, fmat_pr(), mat_free(), mat_malloc(), mat_null(), MATRIX::p, SMALL, SystemComplete, and TRUE. Referenced by Solution_generator(). |
|
||||||||||||||||||||
|
Definition at line 49 of file fsp.c. References BLOCK_COL_FIND_X(), CheckB(), CheckRange(), Solutions::cn, COMPLETE, DEBUG, DEBUG_FSP, FALSE, fmat_pr(), Solutions::g, gcheck, IKerror(), mat_free(), mat_malloc(), mat_null(), Solutions::Mred, Solutions::N, NOT_COMPLETE, Solutions::Nred, Solutions::Null_Space, OK, MATRIX::p, Rebuild_gs(), ReduceA(), RestofSoln(), RESTRICTED, SPAN, SPAN2, SystemComplete, TRUE, Solutions::Xelim, and ZERO. Referenced by avoid_limits(), avoid_obstacles(), and FSP(). |
|
|
Definition at line 131 of file useful_UTILS.c. References Solutions::betall, Solutions::g, mat_free(), Solutions::Qarray, and Solutions::Xelim. Referenced by IKOR_driver(). |
|
||||||||||||
|
Definition at line 93 of file useful_UTILS.c. References Solutions::betall, Solutions::cn, MATRIX::cols, FATAL, Solutions::g, IKerror(), Solutions::M, mat_malloc(), Solutions::Mred, Solutions::N, Solutions::Nred, MATRIX::p, Solutions::Qarray, MATRIX::rows, and Solutions::Xelim. Referenced by IKOR_driver(). |
|
||||||||||||
|
|
|
||||||||||||
|
Definition at line 833 of file IKOR_driver.c. References History::dq, HIST_SIZE, mat_cp(), History_Element::time, and History::whereami. Referenced by FSP(), and IKOR_driver(). |
 1.3.6