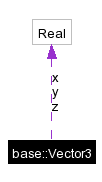
Public Types | |
| enum | Coords { X = 1, Y = 2, Z = 3, Coords3D = 4 } |
Public Member Functions | |
| Vector3 () | |
| Vector3 (Real xc, Real yc, Real zc) | |
| Vector3 (const Vector3 &v) | |
| Vector3 (const osg::Vec3 &v) | |
| ~Vector3 () | |
| void | setZero () throw () |
| bool | isZero () const throw () |
| bool | equalsZero (Real eps=consts::epsilon) |
| Real & | e (Int i) throw () |
| const Real & | e (Int i) const throw () |
| Real & | at (Int i) throw (std::out_of_range) |
| const Real & | at (Int i) const throw (std::out_of_range) |
| Real & | operator[] (Int i) |
| const Real & | operator[] (Int i) const |
| Vector3 & | operator= (const Vector3 &src) throw () |
| bool | operator== (const Vector3 &v) const throw () |
| bool | operator!= (const Vector3 &v) const throw () |
| bool | equals (const Vector3 &v, Real epsilon=consts::epsilon) const throw () |
| Real | norm () const throw () |
| Real | magnitude () const throw () |
| Real | length () const throw () |
| Vector3 & | negate () throw () |
| Vector3 & | normalize () |
| Real | magNormalize () |
| Vector3 & | cross (const Vector3 &p) throw () |
| Vector3 & | cross (const Vector3 &a, const Vector3 &b) throw () |
| Real | dot (const Vector3 &p) const throw () |
| Vector3 & | operator+= (const Vector3 &v2) throw () |
| Vector3 & | operator-= (const Vector3 &v2) throw () |
| Vector3 & | operator *= (const Real &s) throw () |
| Vector3 & | operator/= (const Real &s) |
| Int | largestAxis () const |
| const Real * | c_array () const |
| Real * | c_array () |
| osg::Vec3 | toVec3 () const |
| void | serialize (Serializer &s) |
| read or write object state to Serializer | |
Static Public Member Functions | |
| Vector3 | min (const base::array< Vector3 > &vectors) |
| Vector3 | max (const base::array< Vector3 > &vectors) |
| void | minmax (const base::array< Vector3 > &vectors, Vector3 &minimum, Vector3 &maximum) |
Public Attributes | |
| Real | x |
| Real | y |
| Real | z |
|
|
|
|
|
Definition at line 52 of file Vector3. References base::Real, and z. Referenced by cross(), negate(), normalize(), operator *=(), operator+=(), operator-=(), operator/=(), and operator=(). |
|
||||||||||||||||
|
Definition at line 53 of file Vector3. References base::Real, and z. |
|
|
Definition at line 54 of file Vector3. References operator=(). |
|
|
Definition at line 56 of file Vector3. References z. |
|
|
|
|
|
Definition at line 91 of file Vector3. References Exception, base::Int, base::Real, and z. |
|
|
Definition at line 83 of file Vector3. References Exception, base::Int, base::Real, and z. |
|
|
Definition at line 185 of file Vector3. References base::Real. |
|
|
Definition at line 184 of file Vector3. References base::Real. |
|
||||||||||||
|
|
|
|
Definition at line 155 of file Vector3. Referenced by cross(). |
|
|
Definition at line 161 of file Vector3. References base::Real, and z. Referenced by robot::TestRobot::PlatformControlInterface::getInput(). |
|
|
Definition at line 77 of file Vector3. References Assertm, base::Int, base::Real, and z. |
|
|
Definition at line 71 of file Vector3. References Assertm, base::Int, base::Real, and z. Referenced by base::Quat4::at(), base::Quat4::e(), and operator[](). |
|
||||||||||||
|
Definition at line 129 of file Vector3. References base::equals(), base::Real, and z. Referenced by gfx::Line3::contains(), physics::OBBCollisionModel::Moment::equals(), gfx::Triangle3::equals(), gfx::Segment3::equals(), gfx::Line3::equals(), gfx::Disc3::equals(), and base::Quat4::equals(). |
|
|
Definition at line 68 of file Vector3. References base::equals(), base::Real, and z. |
|
|
Definition at line 65 of file Vector3. References z. |
|
|
Definition at line 177 of file Vector3. References base::abs(), base::Int, base::Real, and z. Referenced by physics::BoundingBox::longestAxis(). |
|
|
Definition at line 143 of file Vector3. References magnitude(), and base::Real. Referenced by gfx::Line3::distanceTo(), magNormalize(), normalize(), and gfx::Plane::Plane(). |
|
|
Definition at line 140 of file Vector3. References norm(), base::Real, and base::sqrt(). Referenced by length(). |
|
|
Definition at line 152 of file Vector3. References Assert, length(), base::Real, and z. |
|
|
|
|
|
|
|
||||||||||||||||
|
|
|
|
Definition at line 146 of file Vector3. Referenced by base::Quat4::conjugate(), and base::Quat4::negate(). |
|
|
Definition at line 137 of file Vector3. References base::Real, and z. Referenced by magnitude(). |
|
|
Definition at line 149 of file Vector3. References Assert, length(), base::Real, Vector3(), and z. Referenced by gfx::Disc3::Disc3(), robot::TestRobot::PlatformControlInterface::getInput(), gfx::Line3::Line3(), gfx::Triangle3::normal(), gfx::Line3::operator=(), gfx::Disc3::operator=(), and gfx::Plane::Plane(). |
|
|
Definition at line 171 of file Vector3. References base::Real, Vector3(), and z. |
|
|
Definition at line 121 of file Vector3. References z. |
|
|
|
|
|
|
|
|
Definition at line 174 of file Vector3. References base::Real, Vector3(), and z. |
|
|
Definition at line 105 of file Vector3. Referenced by Vector3(). |
|
|
Definition at line 114 of file Vector3. References z. |
|
|
Definition at line 102 of file Vector3. References e(), base::Int, and base::Real. |
|
|
Definition at line 99 of file Vector3. References e(), base::Int, and base::Real. |
|
|
read or write object state to Serializer
Referenced by base::Serializer::operator()(). |
|
|
Definition at line 62 of file Vector3. References base::Real, and z. Referenced by base::Transform::getTranslation(). |
|
|
Definition at line 187 of file Vector3. References z. |
|
|
|
 1.3.6